IO61X Usage Notes
IO61X Usage Notes — Usage information about
the CAN I/O modules
CAN Message Types
The CAN and CAN FD messages are defined using the CAN_MESSAGE_BUS and
CAN_FD_MESSAGE_BUS Simulink bus datatypes, which contain individual signals for the
different properties of the message. For CAN, a non-bus datatype is available to
support the "SAE J1939" and "XCP over CAN" Simulink blocks. With the exception of
these two use cases, using the non-bus datatype is not recommended.
The CAN_MESSAGE_BUS and the CAN_FD_MESSAGE_BUS datatypes contain the following
signals:
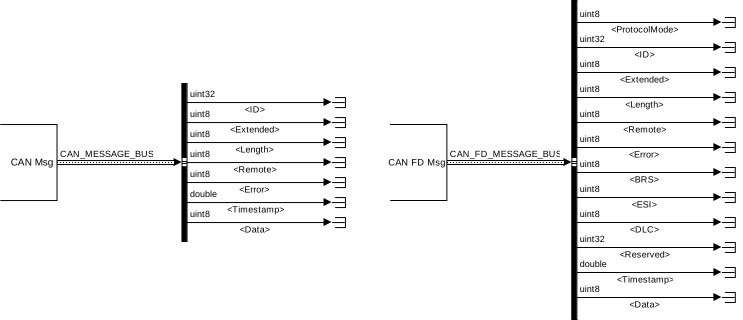
To create a bus object in the base workspace for the Simulink CAN and CAN FD
message bus, refer to the MathWorks VNT documentation for canMessageBusType and canFDMessageBusType.
CAN and CAN FD Message Bus Signals
(* only used with CAN FD messages.)
CAN Read Modes
The CAN Read block can be used in one of two different read modes: Single Read from Buffer (FIFO) and Specify by IDs. This defines how the CAN messages are read from the
bus.
Single Read from Buffer (FIFO)
With Single Read from Buffer (FIFO), all CAN
messages that are available on the specified CAN channel are stored in a message
queue, which is implemented as a First-In-First-Out (FIFO) buffer. In this mode, the
CAN Read block has direct access to this buffer and if there are messages in the
message queue, the Data present outport will be 1.
With every execution of the CAN Read block, one single message is read from the
queue and output on the CAN Msg output port.
To ensure that the complete receive buffer is processed and emptied in one sample
step, the CAN Read block must be executed multiple times until the Data present outport indicates that there are no messages
remaining in the queue. This can be achieved with a do-while subsystem construction,
which will result in multiple iterations of the complete subsystem. Consequently,
every CAN message that has been read from the bus can be processed individually and
the complete buffer is cleared in every sample step.
The maximum number of iterations is set in the While Iterator block in the
Simulink/Ports & Subsystem library. It can be set to unlimited iterations with
(-1) but it is best practice to limit this to 500 iterations.
Inside the subsystem, multiple CAN or CAN FD unpack blocks can be directly
connected to the CAN Msg output port. The matching
IDs are then unpacked into the signals of the message and can be routed out of the
subsystem. If multiple messages with the same Message ID are received, only the most
recent messages will appear in the do-while subsystem output.
The sample time of the subsystem is defined by Simulink inheritance rules: If the
subsystem does not have input ports, it will inherit the fundamental sample time of
the model. Alternatively, the sample time of the subsystem can be controlled by
adding an input port, with a connected signal that has a defined sample time. The
sample time must be chosen depending on the bus load in order to avoid buffer
overflow during one sample step.
A limitation of this read mode is that there can only be one CAN Read block per
channel configured with the Single Read from Buffer
(FIFO) mode. Therefore, all CAN messages that are received on this
channel, must be processed inside this subsystem.
Top Level View
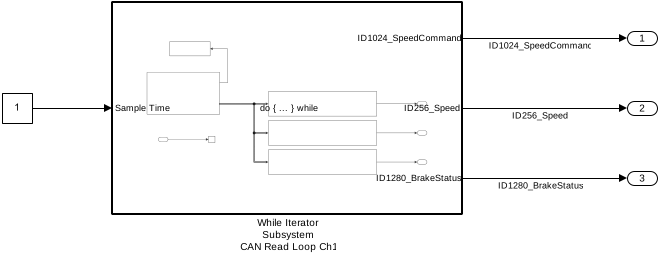
Inside the While Iterator Subsystem
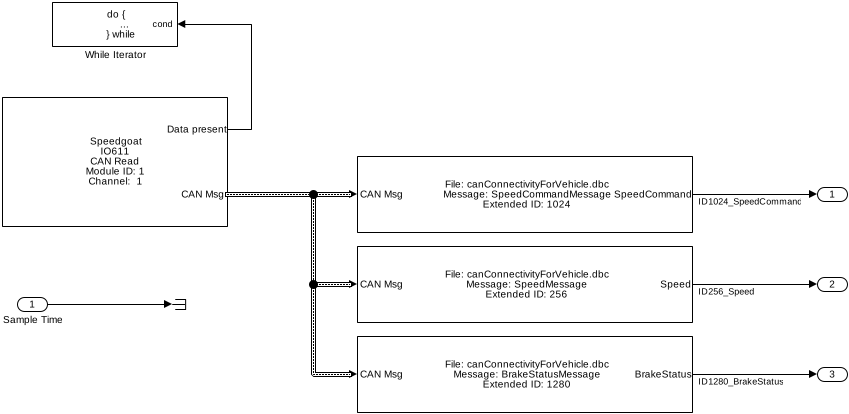
The Sample Time input port defines the rate at
which the subsystem is executed. If the Sample Time
is not defined, the subsystem will run on the base rate.
Specify by IDs
If the application only requires specific CAN IDs and the most recent data of a
CAN message, the Specify by IDs read mode can be
used. In this mode, no While Iterator block is required and the number of CAN Read
blocks per CAN channel is not limited. When reading the same ID with different CAN
Read blocks, execution with different sample times is supported and all the blocks
will read the most recent CAN message.
Initialization and Termination CAN Messages
The CAN Setup driver block allows users to define individual CAN messages to be
sent during initialization and termination of the real-time application. This
functionality can be used to initialize or terminate other CAN nodes (such as data
loggers) on the network.
The initialization and termination CAN messages must be defined with structure
arrays that require the following specific field names:
Channel: Selects the CAN channel on which the message is sent.
Protocol: Defines the protocol type of the message to be either CAN or
CAN-FD. The permitted data range is automatically adjusted to [0 8] byte for
CAN or [0 64] byte for CAN-FD.
BRS: Defines whether the fast data baud rate should be used for CAN-FD.
Valid values are either 0 for standard baud rate or 1 for fast data baud
rate (double).
Type: Defines whether the message to be sent is of a standard or extended
type. Valid values are either Standard or
Extended (character vectors).
Identifier: Defines the identifier of the message. The value (scalar) must
be in the corresponding identifier range (standard or extended).
Data: Defines the data frame to be sent out along with the CAN message.
The length of the row vector defines the data frame size. The limits depend
on the selection made for the Protocol
parameter.
Pause: Defines the amount of time, in seconds, that the Setup block waits
after a message has been sent before sending the next message. Valid values
are 0–0.05 seconds. Some CAN nodes need time to settle before they can
accept the next message; for example, the node must settle when the previous
message sets a new operational mode. Use this field to specify the idle
times.
Initialization and Termination Structure
In MATLAB, the following script can be used to create the initialization and
termination structure. The initCAN and termCAN variables must be specified in the
CAN setup block for the Initialization Structures
Array and Termination Structures
Array fields.
% create Initialization structure
initCAN.Channel     = 1;
initCAN.Protocol    = 'CAN-FD';         % 'CAN' or 'CAN-FD'
initCAN.BRS         = 1;                % 0 or 1
initCAN.Type        = 'Standard';       % 'Standard' or 'Extended'
initCAN.Identifier  = 99;               % ID must be double
initCAN.Data        = [8 8 8 8 8 8 8 8];
initCAN.Pause       = 0.05;

% create Termination structure
termCAN.Channel     = 1;
termCAN.Protocol    = 'CAN-FD';         % 'CAN' or 'CAN-FD'
termCAN.BRS         = 1;                % 0 or 1
termCAN.Type        = 'Extended';       % 'Standard' or 'Extended'
termCAN.Identifier  = double(0xFFF);    % ID must be double
termCAN.Data        = [1 1 1 1 1 1 1 1];
termCAN.Pause       = 0.05;
Baud Rate Configuration
The IO61X I/O modules offer both pre-defined Baud Rates and custom
configurations.
The CAN driver uses a CAN Controller, which monitors the serial bus line and
performs sampling and adjustment of the sample point by synchronizing with the
start-bit edge and resynchronizing with the following edges.
According to the CAN specification, the nominal bit time is split into four segments:
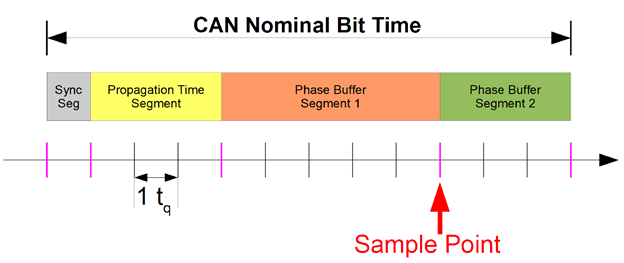
The basic time unit of the CAN Nominal Bit Time is time quantum (t_q). The length
of one time quantum is determined by the clock rate of the CAN controller and a Baud
Rate Prescaler. While the synchronization segment has a fixed length, the other
three sections are programmable.
Sync Seg: The Synchronization Segment (Sync Seg) has a fixed length of one
time quantum (1 t_q). The edges of the bus level are expected to occur
during the Sync Seg. If an edge occurs outside of Sync Seg, its distance is
called the phase error of this edge. On the other hand, if the edge occurs
before Sync Seg, the phase error is negative.
Prop Seg: The Propagation Time Segment (Prop Seg) compensates for the
physical delay times within the CAN network. These delay times consist of
the signal propagation time on the bus and the internal delay time of the
CAN nodes.
Phase Seg1: The Phase Buffer Segment 1 (Phase Seg1) compensates for
positive phase errors and may be lengthened during resynchronization. The
end of this segment defines the Sample Point (SP).
Phase Seg2: The Phase Buffer Segment 2 compensates for negative phase
errors and may be shortened during resynchronization.
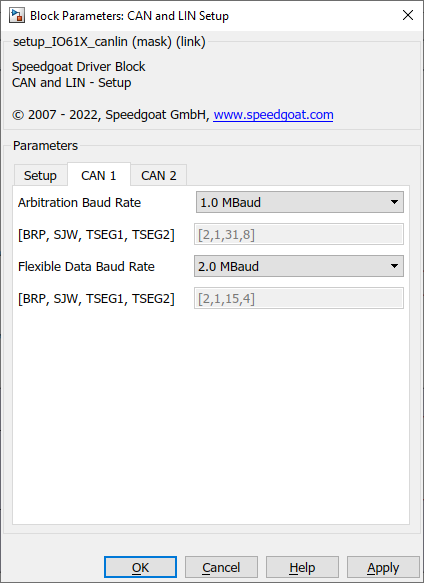
Baud Rate parameters:
BRP: Baud Rate Prescaler (BRP). The bit time quantum (t_q) is obtained by
dividing BRP by the CAN controller clock rate (CAN_Clk = 80.000.000 [Hz]).
SJW: Synchronization Jump Width (SJW) value used for the synchronization.
This will be SJW + 1. The SJW value must not exceed the time quanta assigned
to Phase Buffer Segment 1.
TSEG1: Time segment before the sample point. This covers the Propagation
Time Segment and Phase Buffer Segment 1. The TSEG1 value used for the bit
timing will be TSEG1 + 1.
TSEG2: Time segment after the sample point. The TSEG2 value used for the
bit timing will be TSEG2 + 1. The minimum value of TSEG2 is the configured
SJW.
The following formulas are used for calculating the CAN bit rate:
t_q = BRP / CAN_Clk
t_BS1 = t_q * (TSEG1 + 1)
t_BS2 = t_q * (TSEG2 + 1)
NominalBitTime = t_q + t_BS1 + t_BS2 = t_q * (1 + TSEG1 + TSEG2)
CAN Baud rate = 1/NominalBitTime
Depending on the cable length and machine setup, the Sample-Point can be rather
late, for example, 87.5% (recommended value from CiA).
Remote frames
 | Note |
|---|
For reading Remote Frames with an IO61X channel works solely with the Read
block parameter Read Mode set to Single Read from Buffer (FIFO) |
| Note |
|---|
When using Remote Frames with the IO61X modules, alongside with the Rtr bit
being set, the DLC has to set to zero. This
applies to both CAN Pack and CAN Unpack blocks. |
Usage of LIN Pack and Unpack Blocks
In order to support the Simulink LIN Pack and Unpack blocks, the DLC parameter for
the respective LIN Write and Read block must always be set to 8. Unused data fields
are filled with zero.
When reading LIN messages in a triggered subsystem, as recommended, the output of
the Enable block must be connected to the Msg
Updated input of the LIN Unpack block.
To successfully load a LIN Descriptor File (.ldf), the following requirements must
be met:
The line endings in the .ldf file must conform to the Windows style (CR
LF).
Use the .ldf file of the LIN product example as a template.
Do not rearrange the order of the sections in the .ldf file,
delete them or leave them empty. If necessary, placeholder elements
must be added. In the simplest configuration, only the entries
"Signals", "Frames" and "Signal Encoding Types - physical_value"
have an influence on the functionality of the LIN Pack and Unpack
blocks.
The "physical_value" encoding type is supported for the "Signal Encoding
Types" section but must not be used due to unhandled cases. All other encoding
types are currently not supported and can therefore be used as
placeholders.
The following functions are supported by the LIN Pack and Unpack blocks: