IO423 - Synchro/Resolver Measurement
IO423 - Synchro/Resolver Measurement — Reads the
IO423 Synchro/Resolver inputs
Library
Simulink Real-Time - Speedgoat
Description
Your model can only contain one of these blocks for each I/O module in your target
machine.
Ports
Inputs
-
Max RPS
The maximum rotational velocity. Units are RPS (revolutions per
second). This port is enabled or disabled in the Synchro/Resolver Tab of
the Setup dialog box.
Outputs
-
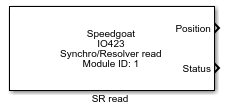
Position
The measured rotational position in radians, degrees or minutes. The
different output units can be selected int the Synchro/Resolver Tab of
the Setup dialog box.
-
Status
The BIT (Built-In-Test) status. The causes for an error are as follow:
Loss of signal (threshold 500mV).
Phase error (input signal is more than 180° different from
reference signal).
Excessive error (digital output is more than 100 LSB's
different from input angle).
Loss of reference (threshold 500mV).
This port is enabled or disabled in the Synchro/Resolver
Tab of the Setup dialog box.
All ports are vectors. The width of the vector, and the order of the
corresponding channels, is dependent on the configuration of the 'Channel vector'
parameter.
Parameters
The configuration details are all defined in the Setup block. They are greyed-out
because they are shown here just for reference.
-
Module ID
This ID defines the link to the corresponding Setup block
-
Sample Time
Defines the base sample time at which this driver block gets its sample hit. This
parameter can also be set to -1 for inherited
sample time. The units are in seconds.